Home / Applications
Application notes
Which architecture fits which motion problem
The single most useful question in a servo drive conversation is whether the machine touches something. If it does, force control is on the table; if it does not, you should judge the drive on positioning behaviour instead. This page maps common machine types to the motion pattern each one needs.
Semiconductor die attach
Picking a die off the wafer, placing it onto the substrate, and pressing it down without cracking it.
Pick-and-place with soft landing
Z-axis approach control when the part must touch the target rather than stop above it.
IVD and laboratory pipetting
Liquid handling where the tip must touch the well and the system must not over-press.
Optical focus and alignment
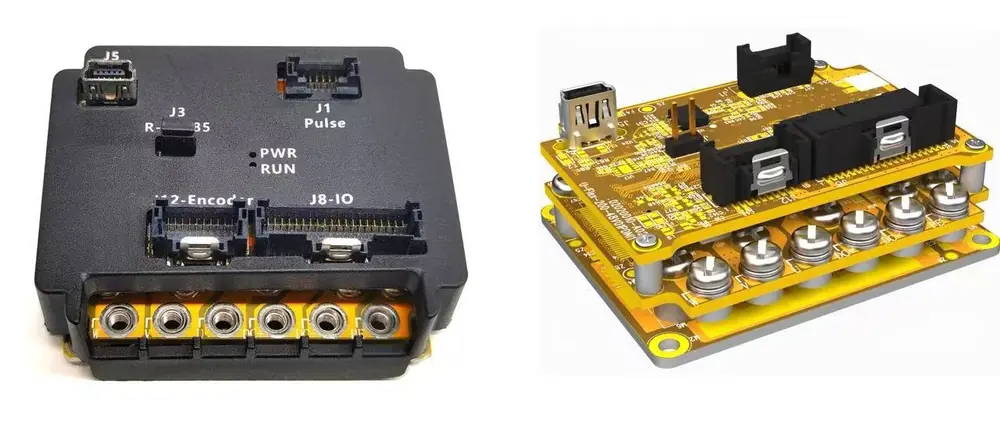
Lens or sensor stages that need to detect contact and stop at a defined force.
Electric grippers and end-effectors
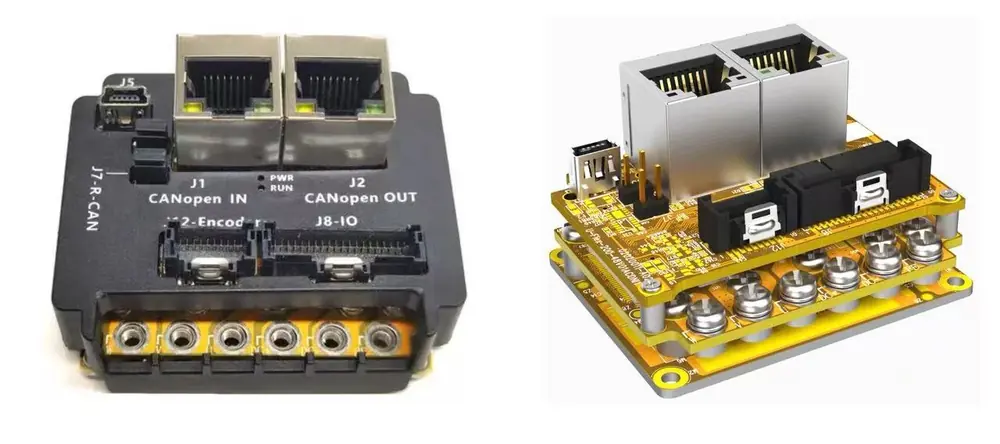
Parallel and angular grippers that need to hold a part with a known force.
Linear XY stages and gantries
Planar stages where positioning accuracy and settling time drive throughput.