Home / Products / UF-48Vxx EtherCAT
Product image · UF-48VxxAEDx
UF-48Vxx EtherCAT 48 V DC servo drive
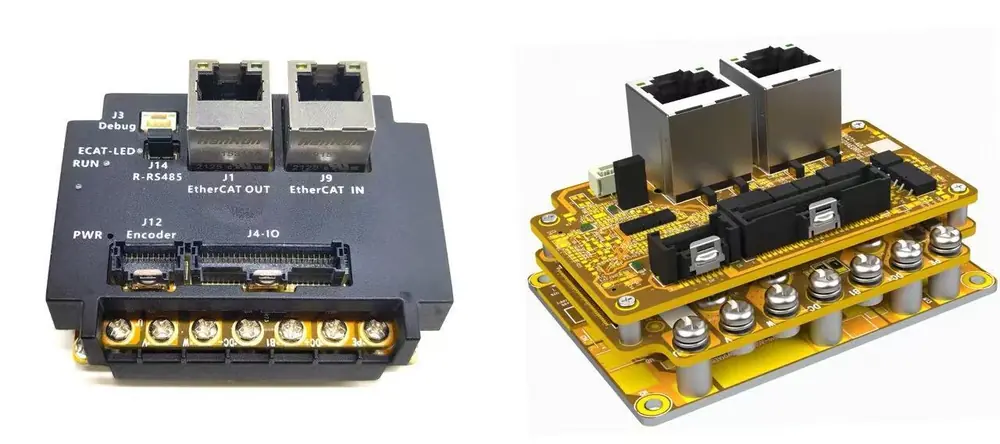
The UF platform with the EtherCAT interface board. This is the variant that supports STO, and the one I specify when a machine has several axes that must move together or when the safety case needs a torque-off function.
| Specification | Value |
|---|---|
| Rated voltage | 24-48 VDC |
| Voltage protection range | 18-62 VDC |
| Current range | 1-28 Arms depending on model |
| Current control frequency | 20 kHz, maximum 40 kHz |
| Current sampling | 12-bit standard, 16-bit on -P |
| EtherCAT real-time cycle | ≤ 4 kHz |
| STO | 2 inputs, 1 output - R-suffix models only |
| Operating temperature | 0 to +45 °C |
What to know about this drive
- EtherCAT variants use RS485 for commissioning daisy-chaining between drives of the same type; the other three interfaces use MiniUSB.
- The
-Psuffix adds 0.1 g force-control resolution and 16-bit current sampling. - EtherCAT is the only interface on this platform that supports STO. If your safety case needs it, that decides the bus for you.
Other UF interface options
EtherCAT
Supports STO, and the variant to specify when axes have to be synchronised.
CANopen
Point-to-point bus for single-axis machines. No STO.
Modbus-RTU
Pragmatic when the machine already speaks Modbus everywhere else. No STO.
Pulse and direction
The retrofit route into an existing motion controller. No STO.
Pricing, lead time and the exact ordering code are confirmed on quotation.
Send me the motor model, bus type and axis count and I will come back
with a written answer.